QUT Centre for Robotics, University of Wuppertal, and Osnabrück University at ECCV 2026
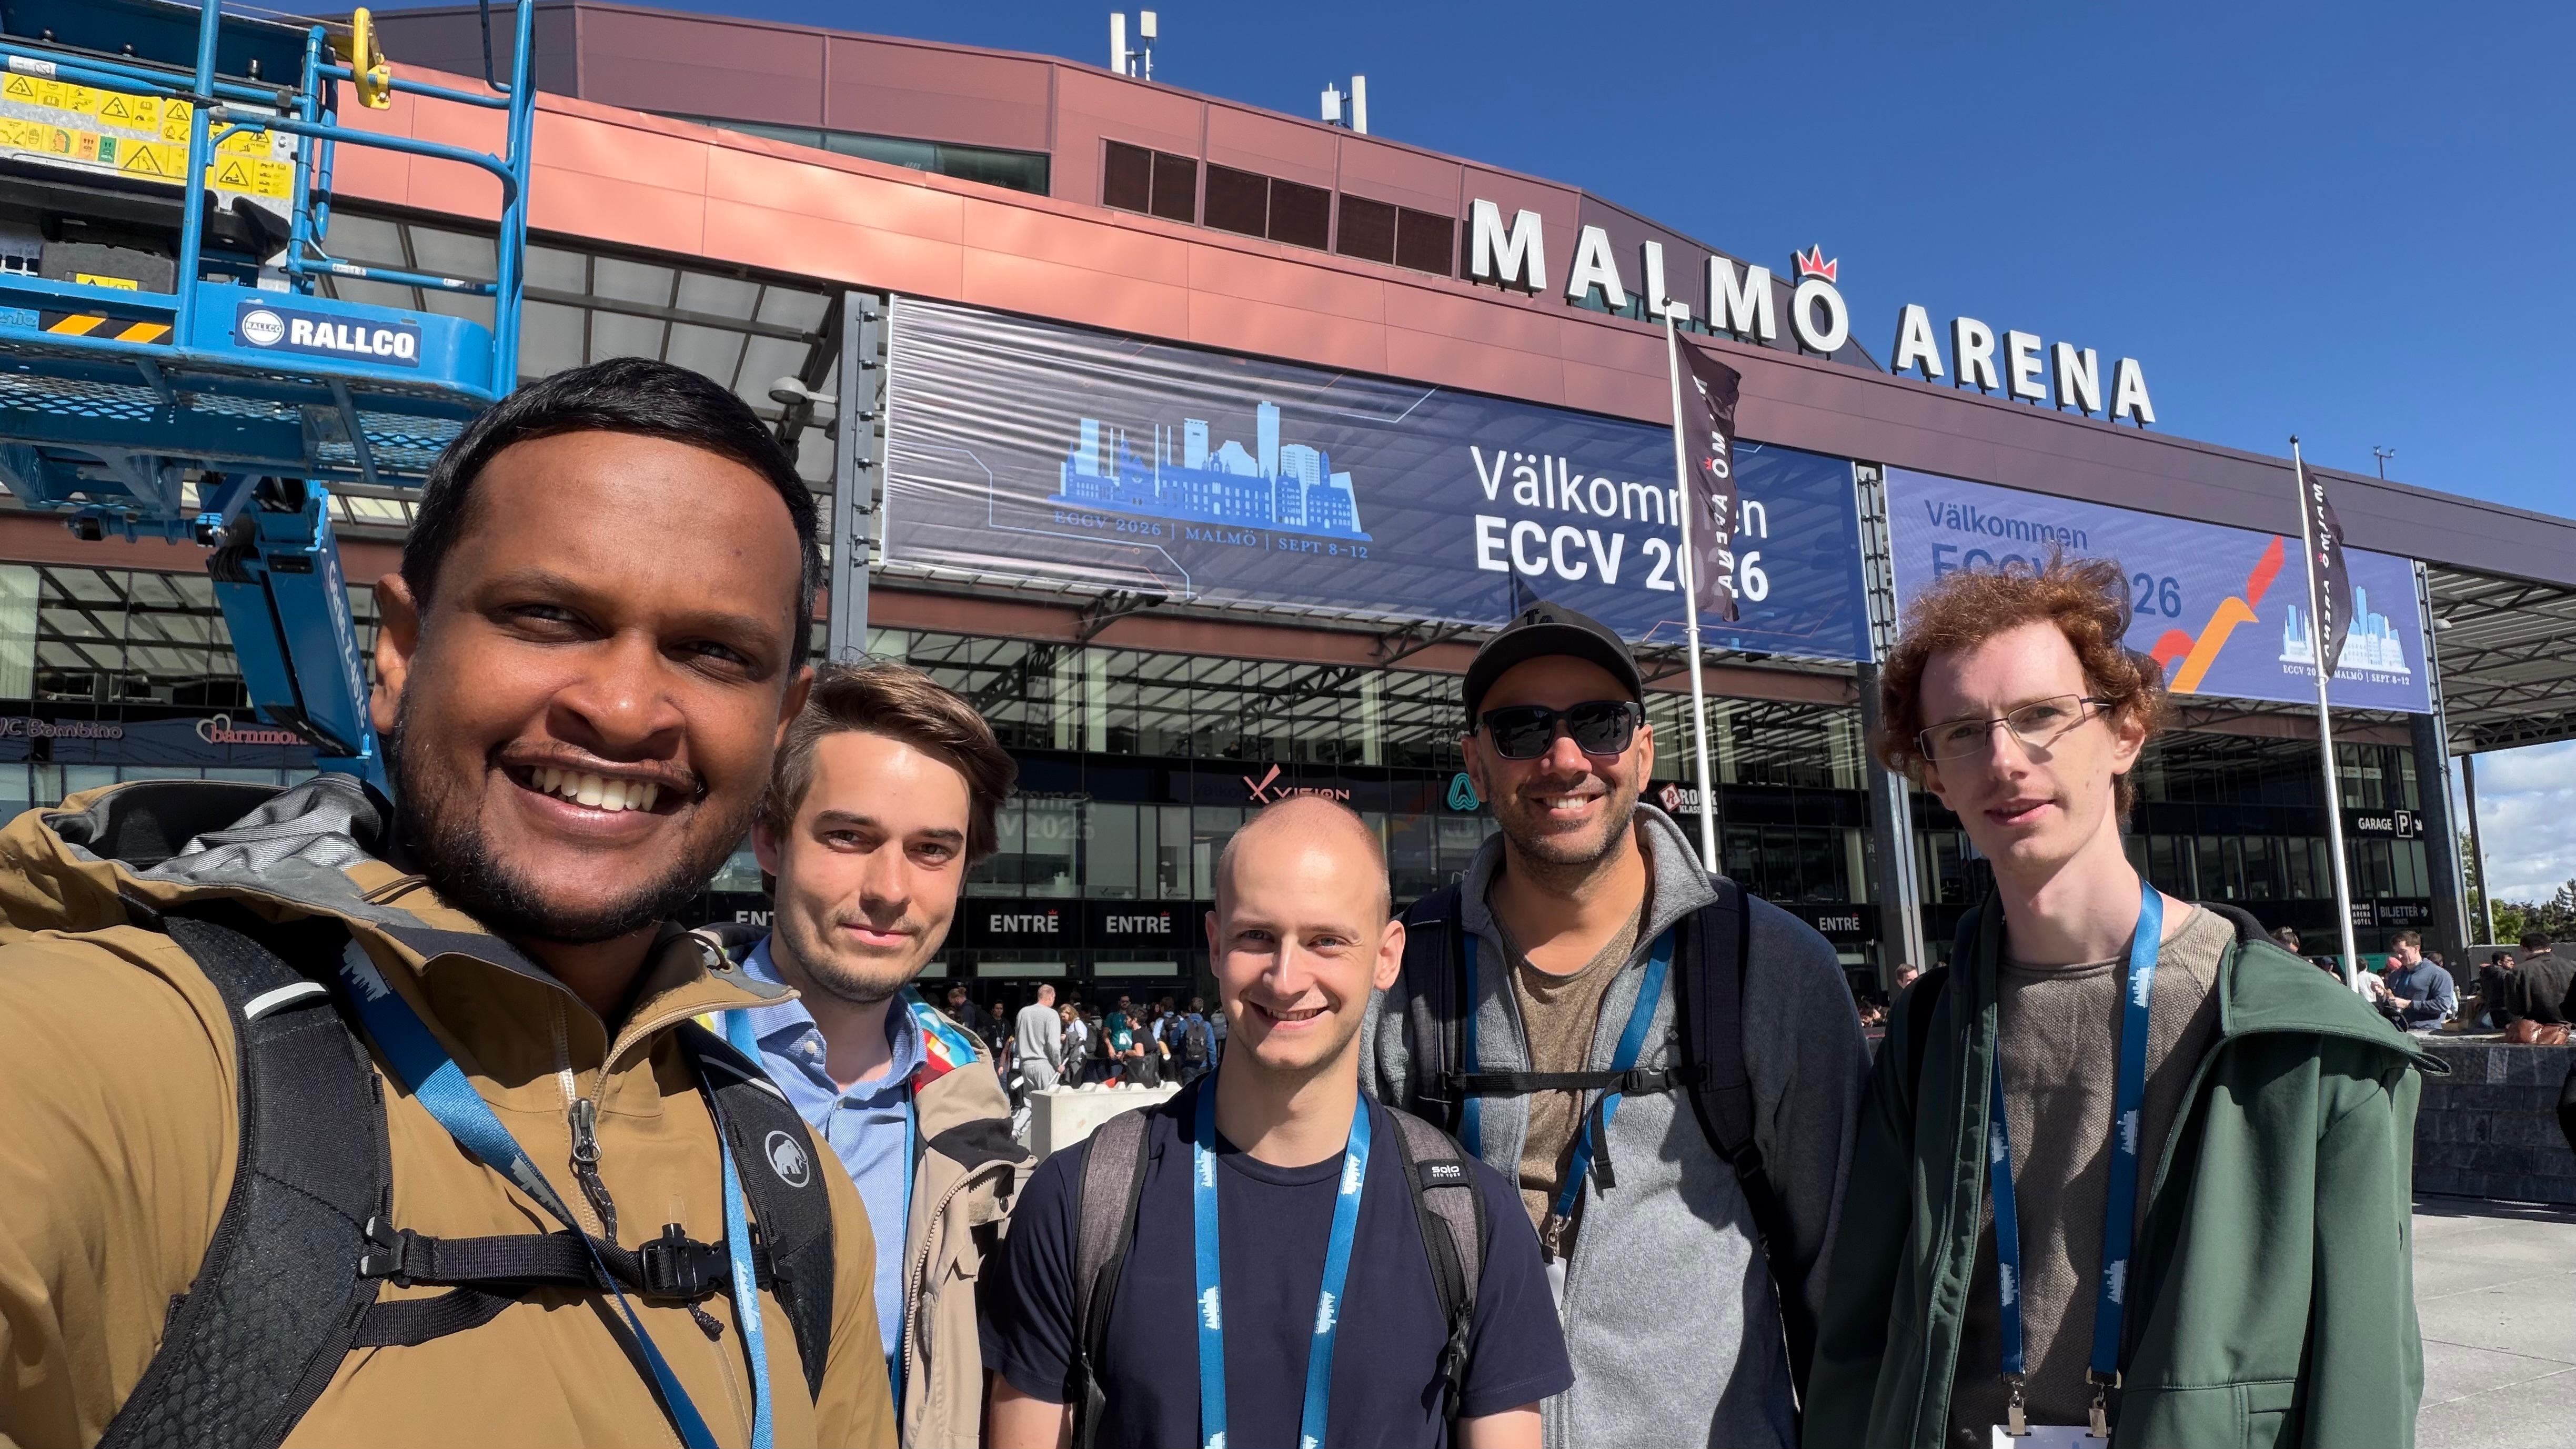
In early September, our team attended ECCV 2026, presenting two works in the areas of uncertainty quantification and data-centric AI.
Predictive Photometric Uncertainty in Gaussian Splatting for Novel View Synthesis
Together with colleagues from the QUT Centre for Robotics, Osnabrück University, and the University of Wuppertal, Chamuditha Jayanga, Thomas Gottwald, Peter Stehr, Edgar Heinert, Niko Sünderhauf, Dimity Miller, and Matthias Rottmann presented a lightweight, plug-and-play framework that brings pixel-wise, view-dependent predictive uncertainty to 3D Gaussian Splatting. This turns it from a pure rendering engine into a trustworthy spatial map for downstream tasks such as active view selection, scene change detection, and anomaly detection.
Paper: https://arxiv.org/abs/2603.22786
Algebraic Multigrid Acceleration for Efficient Label Spreading (AMELS)
At the CDEL Workshop @ ECCV 2026, Antonia van Betteray, Jonathan Klees, Miriam Schäfers, and Matthias Rottmann from Osnabrück University, the University of Wuppertal, and Ruhr University Bochum presented their work AMELS. The approach scales label spreading to millions of data points by combining fast neighborhood graph construction with algebraic multigrid solvers, instead of the usual random-walk iteration. The result: significantly reduced runtime while remaining robust and accurate, even with very few labeled samples.
Paper: https://arxiv.org/abs/2608.26309
Exchange and new connections
The conference offered a great opportunity to connect with the community on uncertainty quantification, data-centric AI, and related topics, and to catch up with both familiar faces and new colleagues. We’re already looking forward to the next opportunity for exchange.